Jingkang Wang

Jingkang Wang    

Staff Machine Learning Engineer
World Models & Simulation
Zoox
Ph.D., University of Toronto

Email:   wangjksjtu (at) gmail (dot) com

LinkedIn  /  Twitter  /  Google Scholar  /  CV

Bio

I am a Staff Machine Learning Engineer at Zoox, working on world models and simulation for autonomous driving. Previously, I was a Staff Researcher and Technical Lead Manager at Waabi, where I led the World Models and Digital Twins team, and a Research Scientist at Uber ATG in Toronto. I received my Ph.D. in Computer Science from the University of Toronto, advised by Raquel Urtasun, and my B.Eng. from Shanghai Jiao Tong University, where I worked with Cewu Lu and Gongshen Liu. As an undergraduate, I also spent a year at UIUC as a research intern with Bo Li, working on trustworthy machine learning.

My research aims to advance world modeling and simulation to enhance physical AI safety, with a focus on self-driving vehicles. I develop scalable and generalizable 4D world simulators from constrained, noisy sensory data using neural rendering and generative AI. Our simulators bridge the gap between simulation and reality, support closed-loop testing (with hardware in the loop), and generate physically plausible counterfactuals to rigorously test and improve autonomy. My long-term goal is to build spatial intelligence into autonomous systems for safer operation in the physical world.


News

  • NEW 2026/09: STRIDE is accepted by NeurIPS 2026. Checkout our latest work on self-supervised, generalizable and decomposable 4D driving scene reconstruction!
  • NEW 2026/06: Joined Zoox as a Staff Machine Learning Engineer to work on world models and simulation. Excited for the new chapter!
  • NEW 2026/03: Gave invited talks "Scaling World Simulators for Safe Physical Intelligence" at UBC, NYU, MIT, UIUC, UW & Ai2, UWaterloo, and Purdue. Thanks to all the hosts!
  • NEW 2026/01: SaLF and GenRe are accepted by ICRA 2026. Checkout our latest works on real-time multi-sensor simulation and generalizable 3D enhancer.
  • NEW 2025/12: I defended my PhD thesis "Scaling Real-world Simulation for Safe Autonomy". Thanks to my advisor Raquel and all my collaborators for the amazing journey!
  • NEW 2025/12: Gave a guest lecture "Perception and Simulation in Autonomous Driving" in 16-820 Advanced Computer Vision at CMU. Thanks Deva for hosting!
  • NEW 2025/10: Gave a guest lecture "Scaling World Simulators for Safe Physical Intelligence" in CS 598 3D Vision at UIUC. Thanks Shenlong for hosting!
  • NEW 2025/09: Flux4D is accepted by NeurIPS 2025. Checkout our latest work on unsupervised generalizable 4D reconstruction!
  • 2025/06: Gave a keynote "Building Safe and Scalable Physical AI Solutions" at CVPR DDADS workshop. Stay tuned for our latest work in unsupervised 4D reconstruction, Flux4D.
  • 2025/03: GenAssets is accepted by CVPR 2025. Checkout our latest work on in-the-wild 360° asset reconstruction and generation.
  • 2025/03: Gave a guest lecture "Introduction to Autonomous Driving" in CPEN 391 at UBC. Thanks Renjie for hosting!
  • 2024/07: G3R is accepted by ECCV 2024. Checkout our latest generalizable large reconstruction model for large scenes (full simulation capacities supported).
  • 2024/05: Congrats to Ava on receiving the Jessie W.H. Zou Memorial Award!
  • 2023/08: LightSim is accepted by NeurIPS 2023. Congrats to Ava and Gary! Checkout our latest neural lighting simulation system for self-driving.
  • 2023/08: Adv3D is accepted by CoRL 2023. Congrats to Jay!
  • 2023/07: Two papers are accepted by ICCV 2023! NeuRas: neural scene rasterization for large urban scenes and LiDAR-DG: paired evaluation paradigm to study lidar simulation domain gap.
  • 2023/06: Waabi research hub online, check websites for UniSim, UltraLiDAR, NeuSim and CADSim!
  • 2023/03: UniSim and UltraLiDAR are accepted by CVPR 2023. Check our latest works in closed-loop sensor simulation (LiDAR + Camera with full controllability) and LiDAR generation!
  • 2023/01: NeuSim is accepted by ICRA 2023: in-the-wild neural object reconstruction.
  • 2022/10: CADSim is accepted by CoRL 2022: part-aware inverse rendering from CAD templates.
  • 2021/11: 2021 Baidu Fellowship Finalist.
  • 2021/10: One paper is accepted by CoRL 2021: cost-aware active learning for autonomy.
  • 2021/09: Two papers are accepted by NeurIPS 2021: min-max attack, robust loss in RL/IL.
  • 2021/07: One paper is accepted by ICCV 2021: trustworthy multi-agent communication.
  • 2021/06: Give a talk "Safety-critical scenario generation for full autonomy testing" in CVPR21 tutorial.
  • 2021/03: Joined Waabi to work on sensor simulation for safe self driving.
  • 2021/03: AdvSim is accepted by CVPR 2021. Check out our framework for mixed-reality LiDAR simulation and safety-critical scenario generation with full autonomy involved.
  • ▸ show older news


  • Publications   (show selected / show all)
    My research interest is to scale the data-driven simulation (realistic, robust, scalable, generalizable, efficient) by inferring or grounding the 3D world (graphics, physics) to ensure the safe deployment of robotic systems.

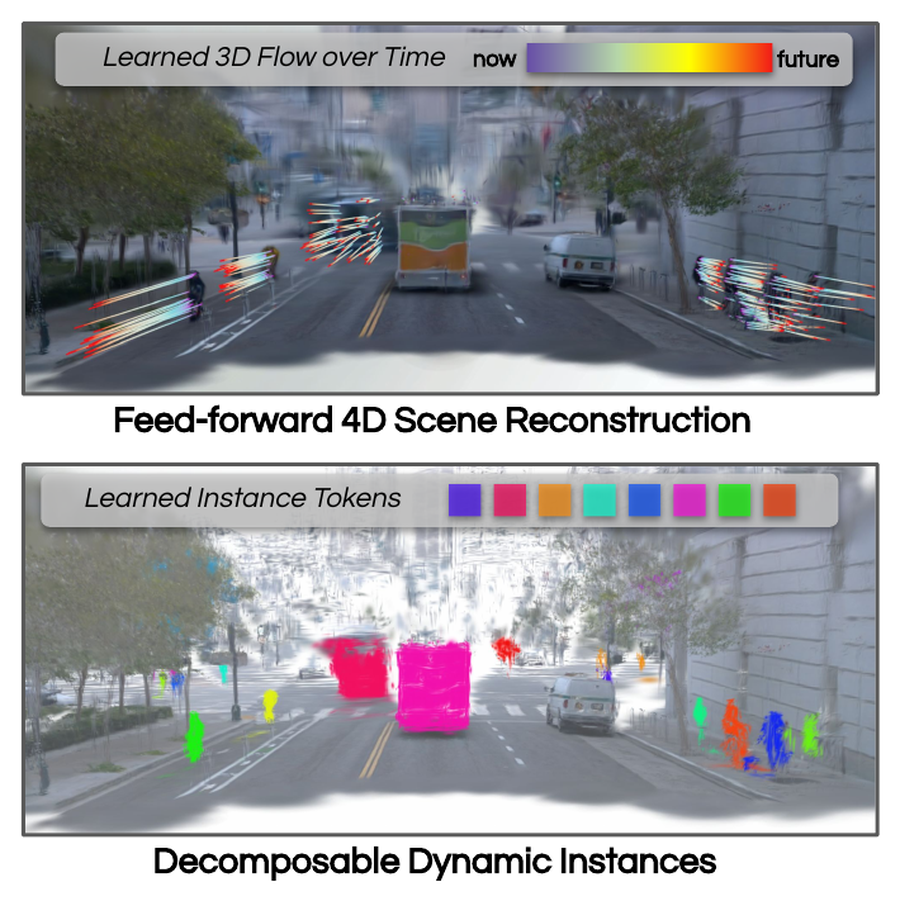
    STRIDE: Towards Self-Supervised, Generalizable and Decomposable 4D Driving Scene Reconstruction
    James Tu*, Anqi Joyce Yang*, Jingkang Wang, Sivabalan Manivasagam, Raquel Urtasun
    Advances in Neural Information Processing Systems (NeurIPS), 2026
    project page / paper / bibtex

    Self-supervised, generalizable and decomposable 4D driving scene reconstruction from camera and LiDAR.
    Diffusion-guided Generalizable Enhancer for Urban Scene Reconstruction
    Henry Che, Jingkang Wang, Yun Chen, Ze Yang, Sivabalan Manivasagam, Raquel Urtasun
    International Conference on Robotics and Automation (ICRA), 2026
    project page / paper / bibtex

    A generalizable 3D enhancer for urban scene reconstruction.
    SaLF: Sparse Local Fields for Multi-Sensor Rendering in Real-Time
    Yun Chen*, Matthew Haines*, Jingkang Wang, Krzysztof Baron-Lis, Sivabalan Manivasagam, Ze Yang, Raquel Urtasun
    International Conference on Robotics and Automation (ICRA), 2026
    project page / paper / bibtex

    A unified representation for multi-sensor simulation in real-time (rasterization + ray tracing).
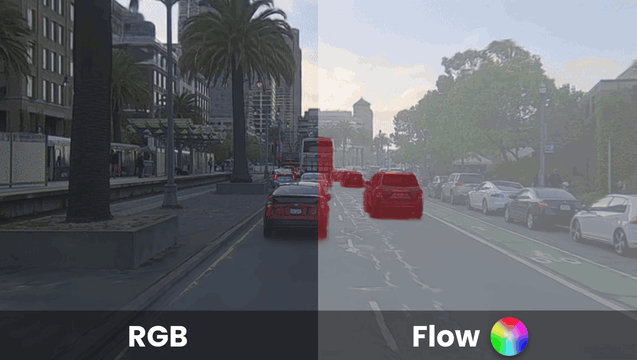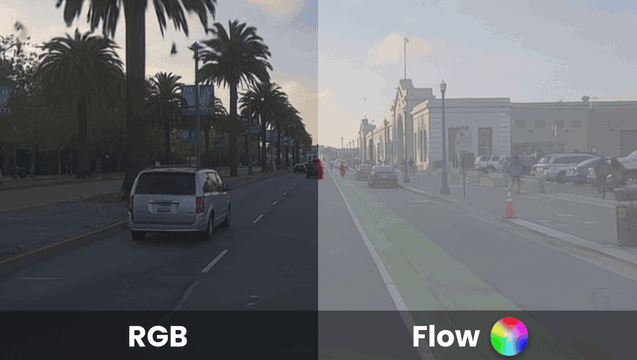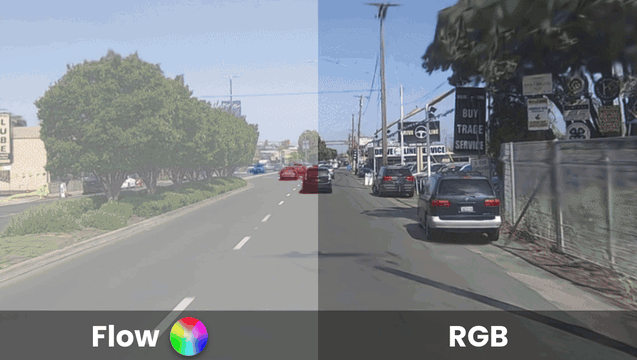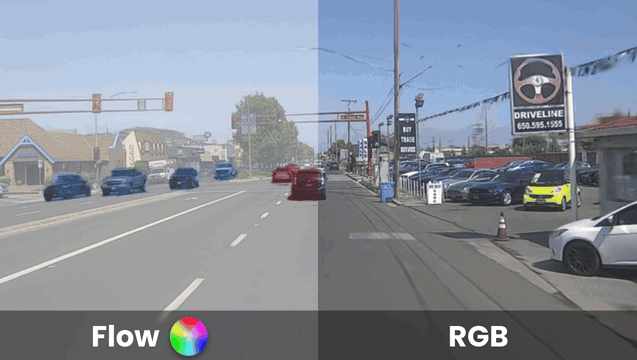
    Flux4D: Flow-based Unsupervised 4D Reconstruction
    Jingkang Wang*, Henry Che*, Yun Chen*, Ze Yang, Lily Goli, Sivabalan Manivasagam, Raquel Urtasun
    Advances in Neural Information Processing Systems (NeurIPS), 2025
    project page / paper / bibtex

    A simple, scalable framework for unsupervised generalizable 4D reconstruction of large-scale driving scenes.
    GenAssets: Generating in-the-wild 3D Assets in Latent Space
    Ze Yang, Jingkang Wang, Haowei Zhang, Sivabalan Manivasagam, Yun Chen, Raquel Urtasun
    Conference on Computer Vision and Pattern Recognition (CVPR), 2025
    project page / paper / bibtex

    Reconstruct or generate 360° assets from in-the-wild images and/or LiDAR point clouds with UniSim + latent diffusion model (LDM).
    G3R: Generalizable Gradient-Guided Reconstruction
    Yun Chen*, Jingkang Wang*, Ze Yang, Sivabalan Manivasagam, Raquel Urtasun
    European Conference on Computer Vision (ECCV), 2024
    project page / paper / bibtex

    A generalizable large simulation model for outdoor dynamic scenes: reconstruct unseen large scenes in 2' and support real-time (FPS>100) full camera simulation.
    LightSim: Neural Lighting Simulation for Urban Scenes
    Ava Pun*, Gary Sun*, Jingkang Wang*, Yun Chen, Ze Yang, Sivabalan Manivasagam, Wei-Chiu Ma, Raquel Urtasun
    Advances in Neural Information Processing Systems (NeurIPS), 2023
    project page / paper / video / 4K demo / bibtex

    A data-driven neural lighting simulation system for urban scenes that generates diverse, controllable, and realistic videos.
    Adv3D: Generating Safety-Critical 3D Objects through Closed-Loop Simulation
    Jay Sarva, Jingkang Wang, James Tu, Yuwen Xiong, Sivabalan Manivasagam, Raquel Urtasun
    Conference on Robot Learning (CoRL), 2023
    project page / paper / video / poster / bibtex

    Closed-loop simulation on real-world scenarios to identify challenging shapes and failure modes.
    Towards Zero Domain Gap: A Comprehensive Study of Realistic LiDAR Simulation for Autonomy Testing
    Sivabalan Manivasagam*, Ioan Andrei Bârsan*, Jingkang Wang, Ze Yang, Raquel Urtasun
    International Conference on Computer Vision (ICCV), 2023
    project page / paper / video / poster / bibtex

    We analyze the impact of LiDAR sensor effects on the full autonomy stack.
    Real-Time Neural Scene Rasterization for Large Scenes
    Jeffrey Liu, Yun Chen*, Ze Yang*, Jingkang Wang, Sivabalan Manivasagam, Raquel Urtasun
    International Conference on Computer Vision (ICCV), 2023
    project page / paper / video / poster / bibtex

    Neural texture features + MLP shader for real-time rendering (>120 FPS for 1080p).
    UniSim: A Neural Closed-Loop Sensor Simulator
    Ze Yang*, Yun Chen*, Jingkang Wang*, Sivabalan Manivasagam*, Wei-Chiu Ma, Anqi Joyce Yang, Raquel Urtasun
    Conference on Computer Vision and Pattern Recognition (CVPR), 2023 (Highlight)
    project page / paper / video / poster / 4K demo / bibtex

    A data-driven closed-loop sensor simulator to generate realistic counter-factual scenarios from single driving pass.
    UltraLiDAR: Learning Compact Representations for LiDAR Completion and Generation
    Yuwen Xiong, Wei-Chiu Ma, Jingkang Wang, Raquel Urtasun
    Conference on Computer Vision and Pattern Recognition (CVPR), 2023
    project page / paper / video / poster / bibtex

    3D World model for LiDAR: VQVAE tokenizer + autoregressive decoding.
    NeuSim: Reconstructing Objects in-the-wild for Realistic Sensor Simulation
    Ze Yang, Sivabalan Manivasagam, Yun Chen, Jingkang Wang, Rui Hu, Raquel Urtasun
    International Conference on Robotics and Automation (ICRA), 2023
    project page / video / poster / bibtex

    Object reconstruction using physics-guided NeRF from sparse and noisy data.
    CADSim: Robust and Scalable in-the-wild 3D Reconstruction for Controllable Simulation
    Jingkang Wang, Sivabalan Manivasagam, Yun Chen, Ze Yang, Ioan Andrei Bârsan, Anqi Joyce Yang, Wei-Chiu Ma, Raquel Urtasun
    Conference on Robot Learning (CoRL), 2022
    project page / paper / video / bibtex

    Inverse rendering (articulated geometry, PBR material, lighting) from CAD templates via energy minimization.
    AdvSim: Generating Safety-Critical Scenarios for Self-Driving Vehicles
    Jingkang Wang, Ava Pun, James Tu, Sivabalan Manivasagam, Abbas Sadat, Sergio Casas, Mengye Ren, Raquel Urtasun
    Conference on Computer Vision and Pattern Recognition (CVPR), 2021
    project page / paper / poster / video / bibtex

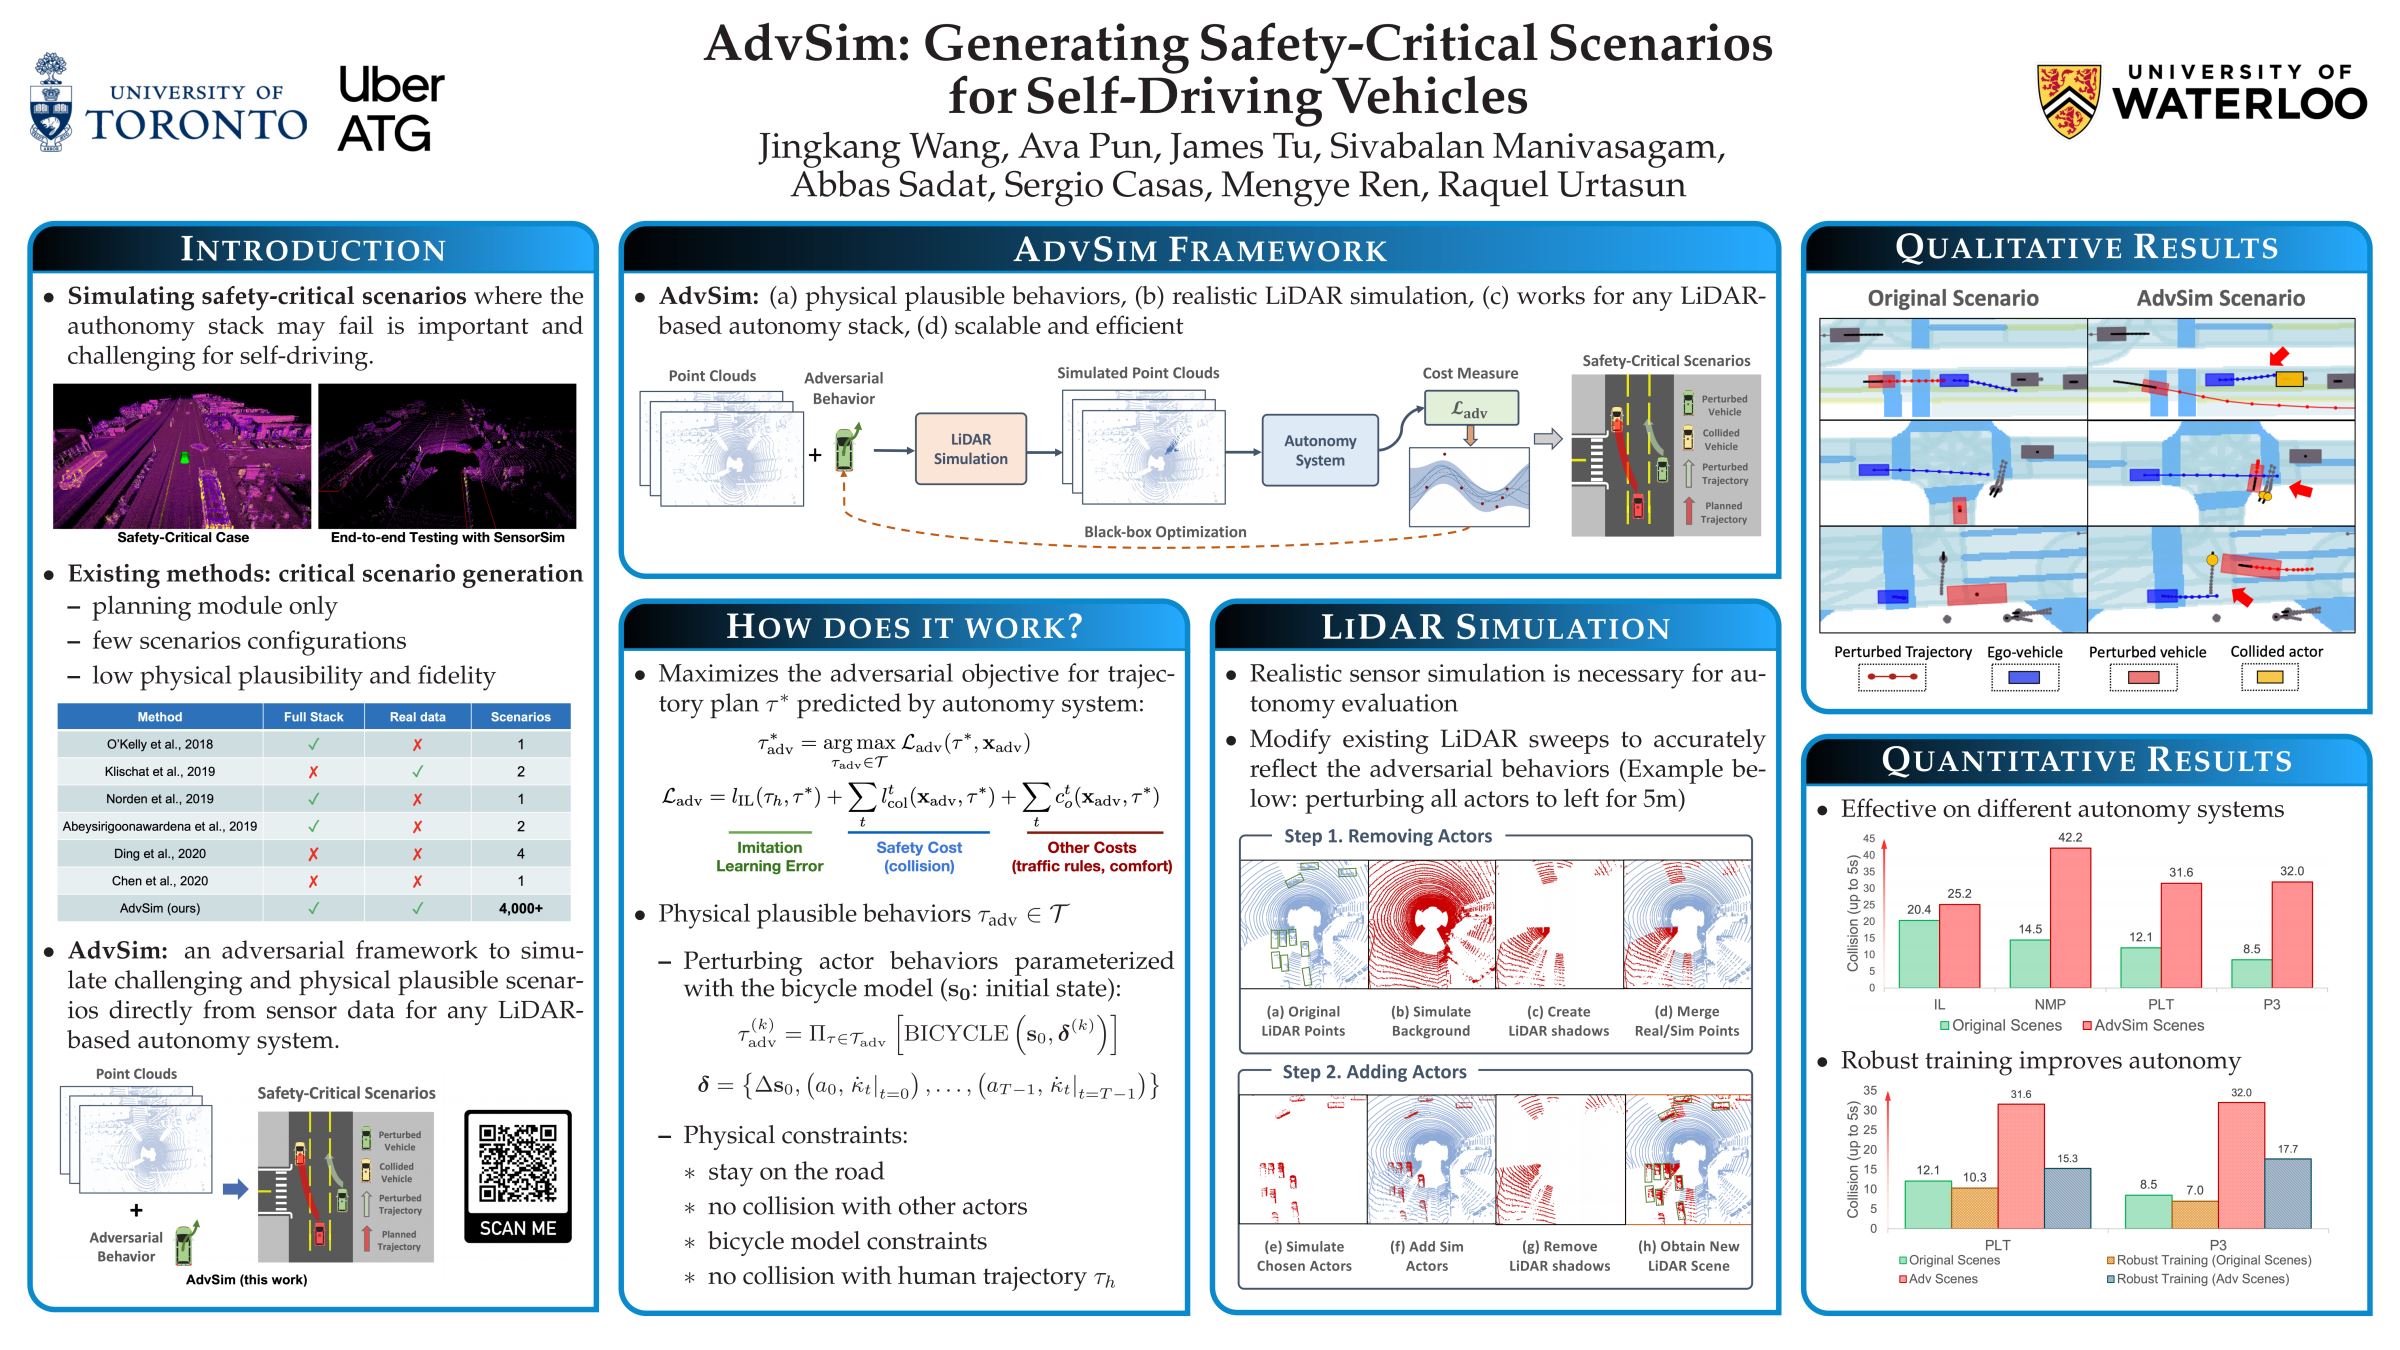
    Safety-critical scenario generation (w.r.t full autonomy stack) using realistic mixed-reality LiDAR simulation and kinematic bicycle model.
    Just Label What You Need: Fine-Grained Active Selection for Perception and Prediction through Partially Labeled Scenes
    Sean Segal*, Nishanth Kumar*, Sergio Casas, Wenyuan Zeng, Mengye Ren, Jingkang Wang, Raquel Urtasun
    Conference on Robot Learning (CoRL), 2021
    paper / poster / bibtex

    Cost-aware active learning allows for fine-grained selection of examples through partially labeled scenes.
    Adversarial Attacks on Multi-Agent Communication
    James Tu*, Tsunhsuan Wang*, Jingkang Wang, Sivabalan Manivasagam, Mengye Ren, Raquel Urtasun
    International Conference on Computer Vision (ICCV), 2021
    paper / video / bibtex

    Adversarial robustness in cooperative multi-agent systems.
    Policy Learning Using Weak Supervision
    Jingkang Wang*, Hongyi Guo*, Zhaowei Zhu*, Yang Liu
    Advances in Neural Information Processing Systems (NeurIPS), 2021
    project page / paper / code / poster / bibtex

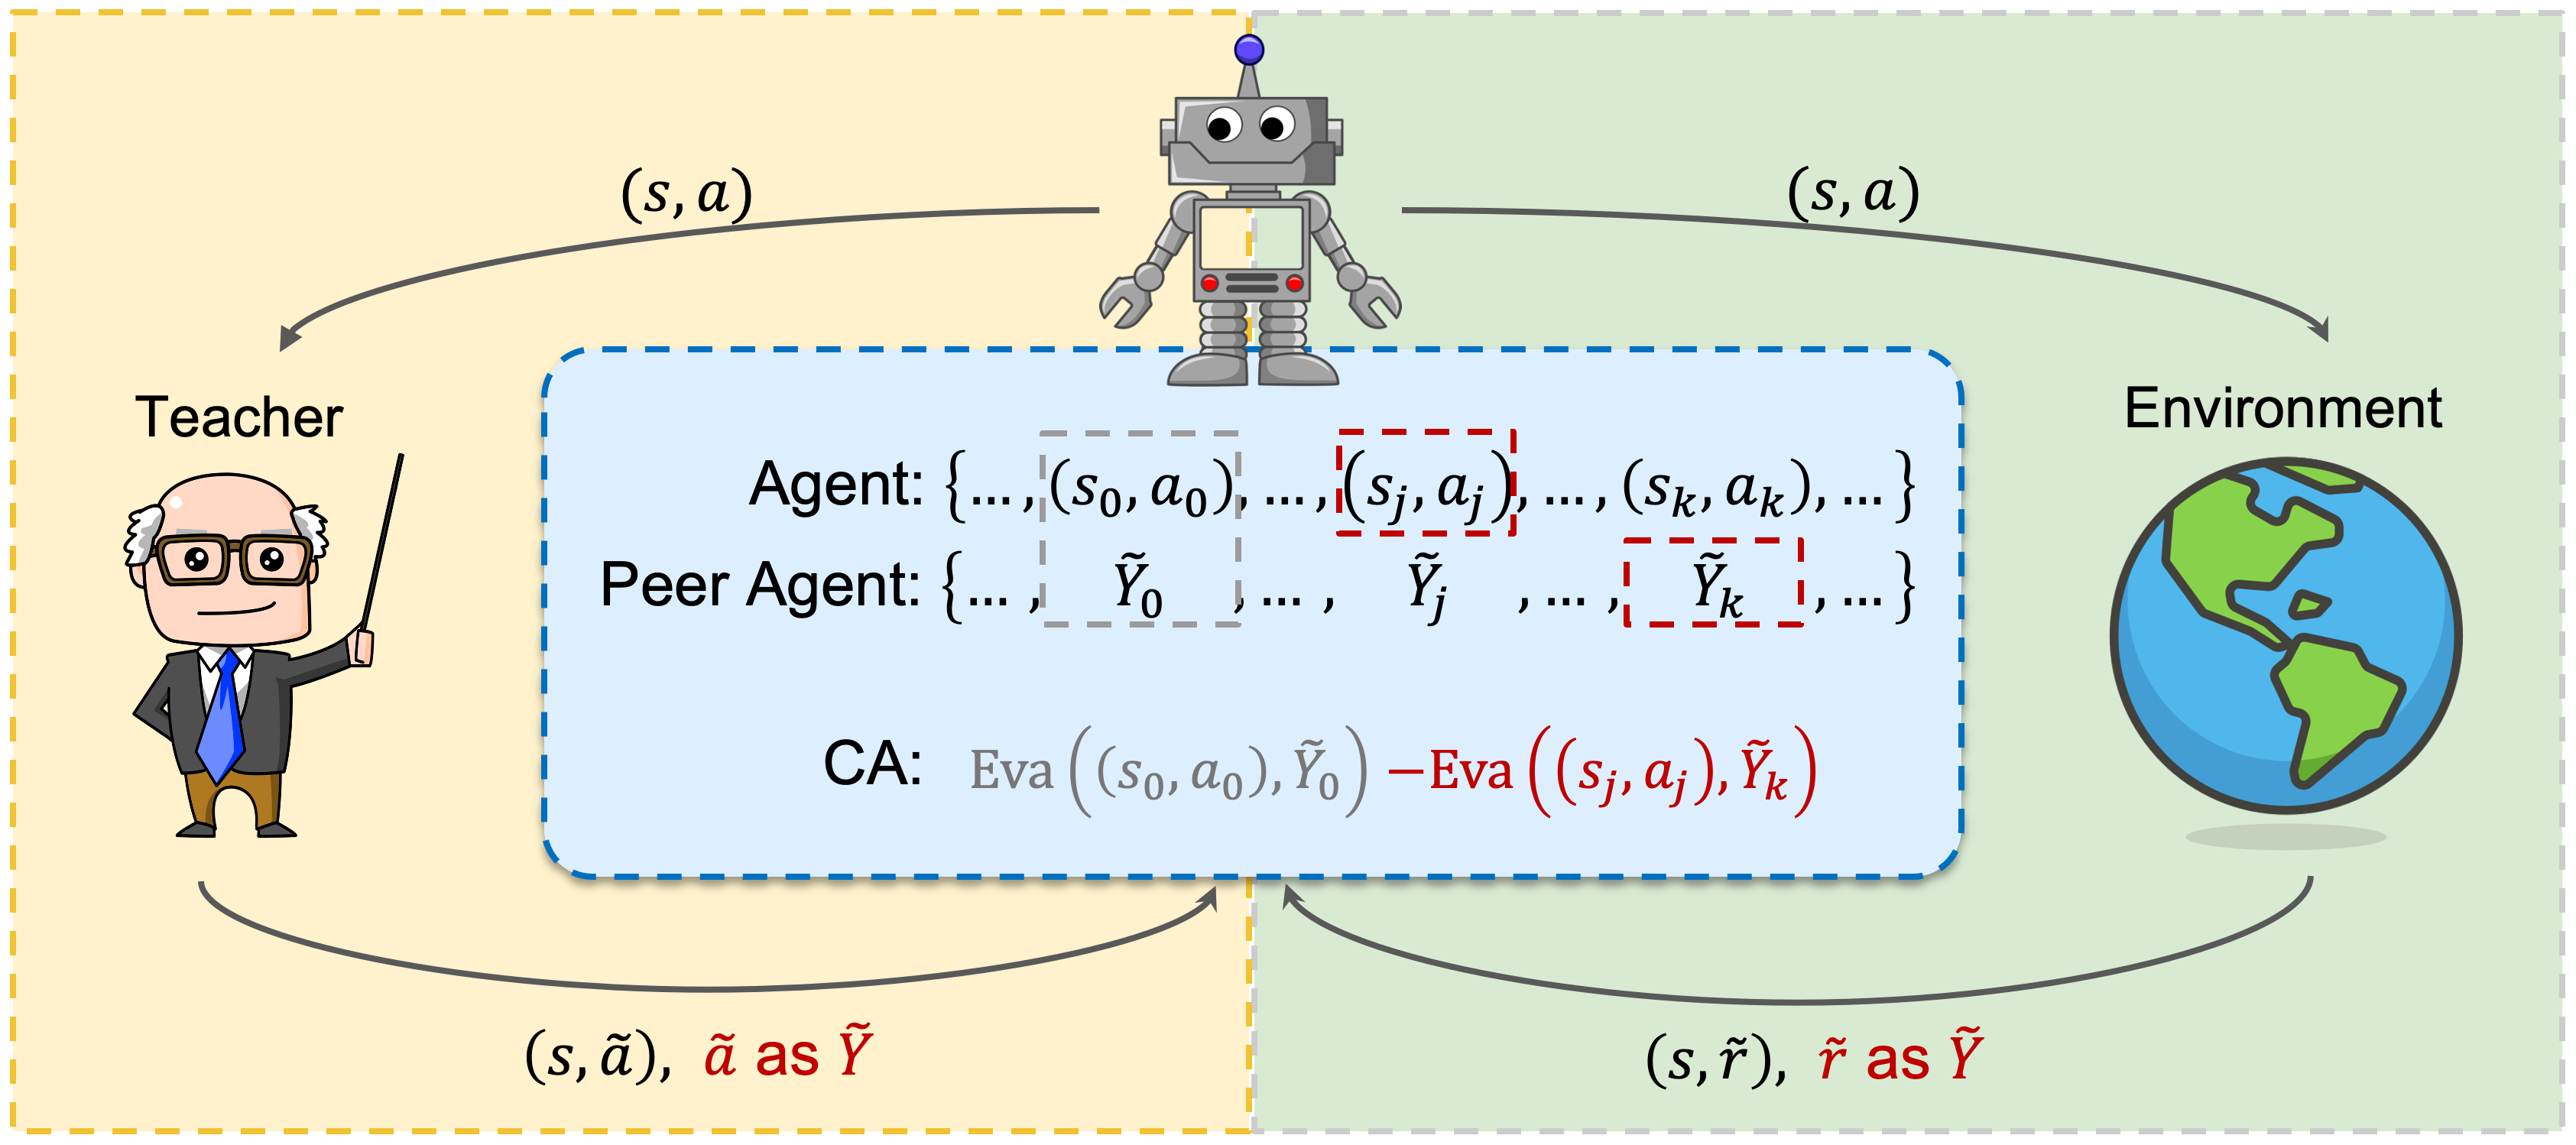
    A framework with correlated aggreement to handle weak supervision in IL/RL.
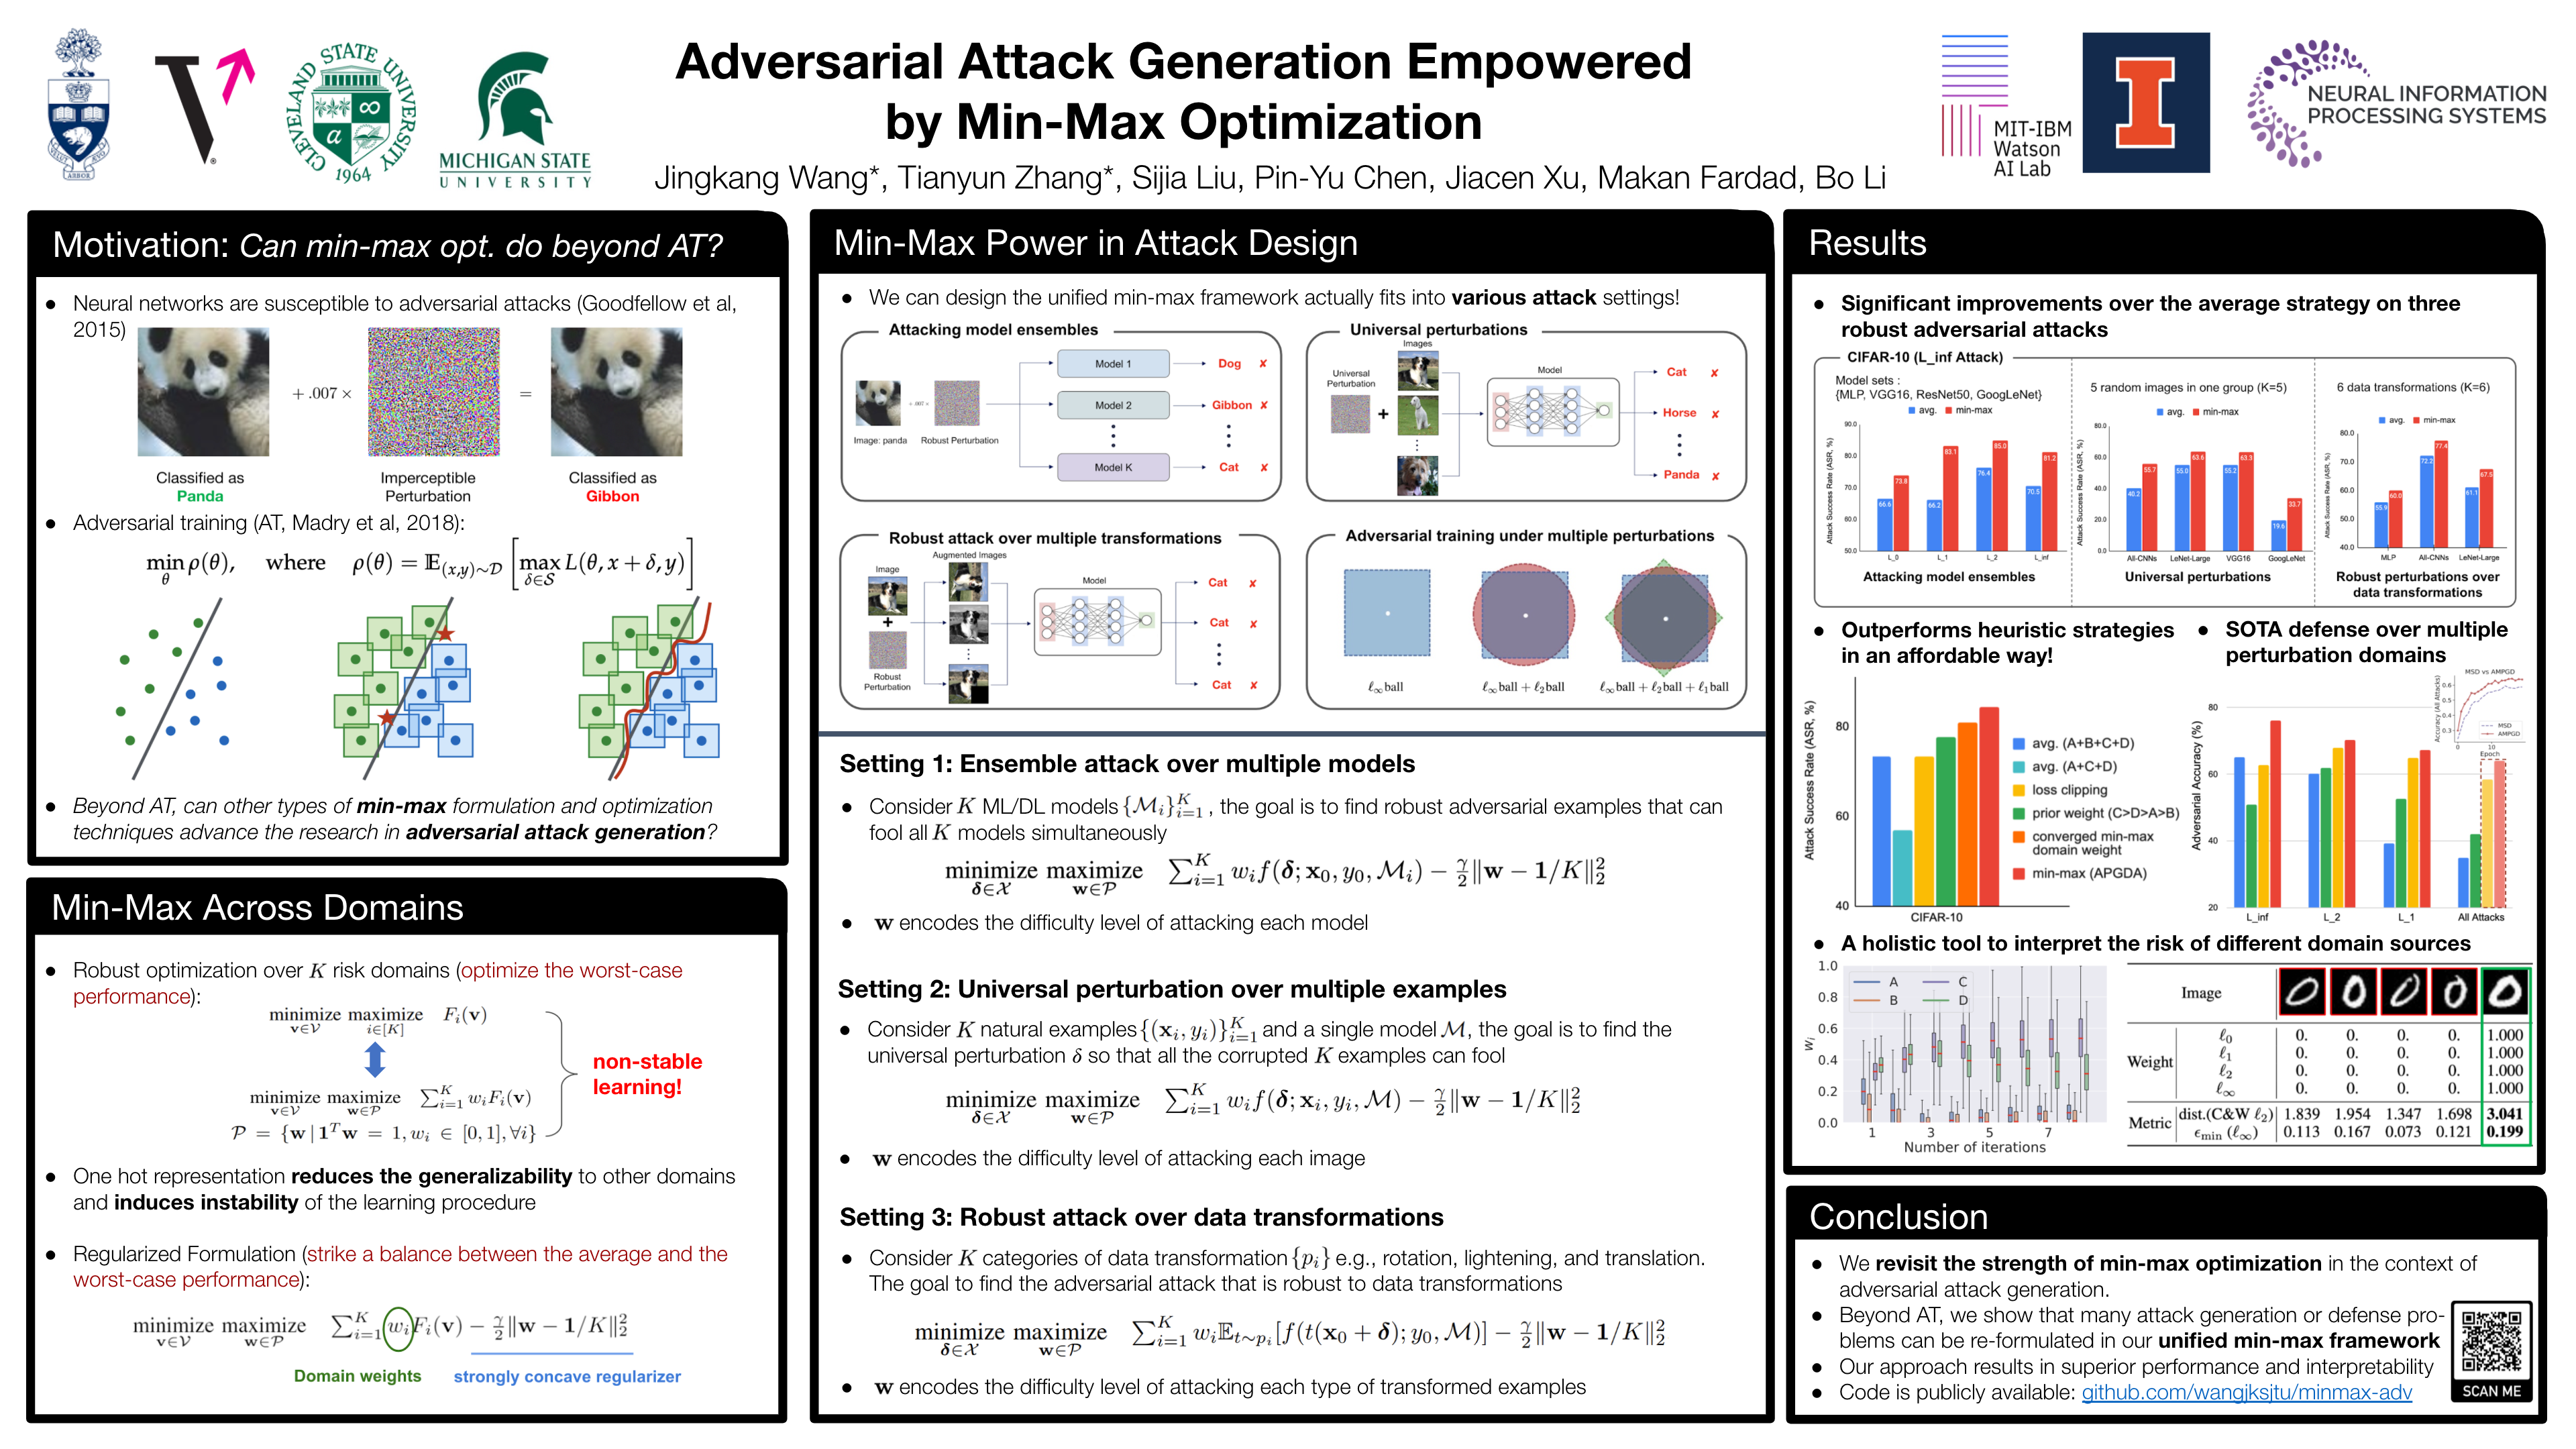
    Adversarial Attack Generation Empowered by Min-Max Optimization
    Jingkang Wang*, Tianyun Zhang*, Sijia Liu, Pin-Yu Chen, Jiacen Xu, Makan Fardad, Bo Li
    Advances in Neural Information Processing Systems (NeurIPS), 2021
    project page / paper / code / poster / bibtex

    A unified adversarial attack/defense by min-max optimization over multiple domains.
    Learning to Communicate and Correct Pose Errors
    Nicholas Vadivelu, Mengye Ren, James Tu, Jingkang Wang, Raquel Urtasun
    Conference on Robot Learning (CoRL), 2020
    paper / video / bibtex

    Robust multi-agent message passing under localization noise.
    Cost-Efficient Online Hyperparameter Optimization
    Jingkang Wang*, Mengye Ren*, Ilija Bogunovic, Yuwen Xiong, Raquel Urtasun
    International Conference on Machine Learning (ICML), RealML Workshop, 2020
    paper / video / bibtex

    Cost-efficient time-varying Gaussian Process (GP).
    Zero-Shot Compositional Policy Learning via Language Grounding
    Tianshi Cao*, Jingkang Wang*, Annie Zhang*, Sivabalan Manivasagam*
    International Conference on Learning Representations (ICLR), BeTR-RL Workshop, 2020
    paper / code / media / bibtex

    Language grounding to improve the generalization of agents across environments with varied dynamics.
    Reinforcement Learning with Perturbed Rewards
    Jingkang Wang, Yang Liu, Bo Li
    AAAI Conference on Artificial Intelligence (AAAI), 2020 (Spotlight)
    paper / code / bibtex

    An unbiased reward estimator that enables RL agent to learn in the noisy environment when only observing perturbed rewards.
    Multiple Character Embeddings for Chinese Word Segmentation
    Jingkang Wang*, Jianing Zhou*, Jie Zhou, Gongshen Liu
    Annual Meeting of the Association for Computational Linguistics (ACL), Student Research Workshop, 2019
    paper / code / bibtex

    Multiple character embeddings (pinyin and wubi) to enhance CWS.
    LiDAR-Video Driving Dataset: Learning Driving Policies Effectively
    Yiping Chen*, Jingkang Wang*, Jonathan Li, Cewu Lu, Zhipeng Luo, Han Xue, Cheng Wang
    Conference on Computer Vision and Pattern Recognition (CVPR), 2018
    project page / paper / code / bibtex

    End-to-end driving policy learned from LiDAR and camera data.

    Honors and Awards

  • Outstanding Reviewer, NeurIPS 2025
  • Baidu Fellowship Finalist (Top 20)
  • Outstanding Reviewer, CVPR 2021
  • National Scholarships
  • SJTU Scholarships (%1)
  • Excellent Bachelor Thesis (Top %1) of SJTU
  • Outstanding Undergraduate in Shanghai
  • First Prize in National College Student Information Security Contest
  • Meritorious Winner Prize in The Mathematical Contest in Modeling (MCM)
  • Second Prize in The Chinese Mathematics Competition (CMC, Shanghai)
  • Second Prize in National College Students Information Security Contest
  • First Prize in Chinese Mathematical Olympiad (CMO, 10th in Shanxi)

  • Work Experience

    Zoox
    Staff Machine Learning Engineer

  • Focus: World Models, Simulation


  • Waabi
    Staff Researcher, TLM

  • Advisor: Professor Raquel Urtasun
  • Focus: World Simulation, AI Safety


  • Uber-ATG Toronto
    Research Scientist

  • Advisor: Professor Raquel Urtasun
  • Focus: Sensor Simulation, AI Safety
  • University of Illinois at Urbana-Champaign
    Research Intern at Secure Learning Lab  

  • Advisor: Professor Bo Li
  • Focus: Trustworthy Machine Learning
  • University of California, Berkeley
    Research Intern at BAIR Lab  

  • Advisor: Professors Bo Li and Dawn Song
  • Focus: Trustworthy Machine Learning

  • Mentorship

    Ava Pun (Undergrad, UWaterloo) safety-critical scenario generation, neural lighting simulation and inverse rendering, now PhD at CMU (first-author ICCV 2025 Best Paper, Marr Prize).
    Gary Sun (Undergrad, UWaterloo) neural lighting estimation and simulation, now Quantitative Researcher at Citadel Securities.
    Jay Sarva (Undergrad, Brown) adversarial closed-loop simulation, now Software Engineer at Databricks.
    Rishi Menon (Undergrad, UWaterloo) generalizable asset reconstruction, now Research Engineer at Waabi.
    Matthew Haines (Undergrad, UWaterloo) scalable and efficient neural rendering, now Research Intern at Tesla.
    Henry Che (Undergrad, UIUC) unsupervised 4D reconstruction, generalizable 3D enhancer, now MS at UIUC and Research Intern at NVIDIA.
    Tao Tu (PhD, Cornell) harmonization and blending with video models.
    Jonathan Leung (Undergrad, UWaterloo) in-the-wild human reconstruction and 2D neural fixer, now Software Engineer Intern at Citadel.
    Alicia Bremer (Undergrad, UWaterloo) unified camera and LiDAR simulation with 3DGS using ray tracing, now Software Developer at Waabi.
    Lily Goli (PhD, UofT) 3D generative models from in-the-wild data.
    Haojun Qiu (Undergrad, UofT) world models, now Researcher at Waabi and PhD at UofT.
    Aom Pong (MS, Georgia Tech) generative reconstruction.
    Daniel Ekpo (PhD, UMD) generalizable reconstruction.


    Service

  • Conference reviewer: ICLR 2024-2025, NeurIPS 2022-2025, ICML 2024, ICCV 2021-2025, CVPR 2021-2025, ECCV 2022-2024, WACV 2024, CoRL 2022, ICRA 2023/2026, IROS 2023, AutoML 2023, ACL 2021-2022, NAACL 2022, EMNLP 2021, KDD 2020
  • Journal reviewer: IJCV, IEEE TIP, IEEE TNNLS, CVIU, T-ITS, IEEE TSP, RA-L

  • Misc

  • Check out my partner Xiaochuan Shi's profile. She currently pursues a Ph.D. in statitics at UofT.
  • I love traveling and explore new places and cultures. So far, I have visited 15 countries and over 40 cities, including Canada, China, United States, Mexico, United Kingdom, Italy, France, Spain, New Zealand, Japan, South Korea, Thailand, Saudi Arabia, United Arab Emirates and Qatar.
  • I am passionate about Chinese calligraphy, especially in regular script (楷书), clerical script (隶书), and semi-cursive script (行书). I also enjoy classical music, particularly the violin (and can play a little), and I am a big fan of anime and movies.


  • Last update: Sept, 2026.

    Thanks jonbarron for this amazing work.