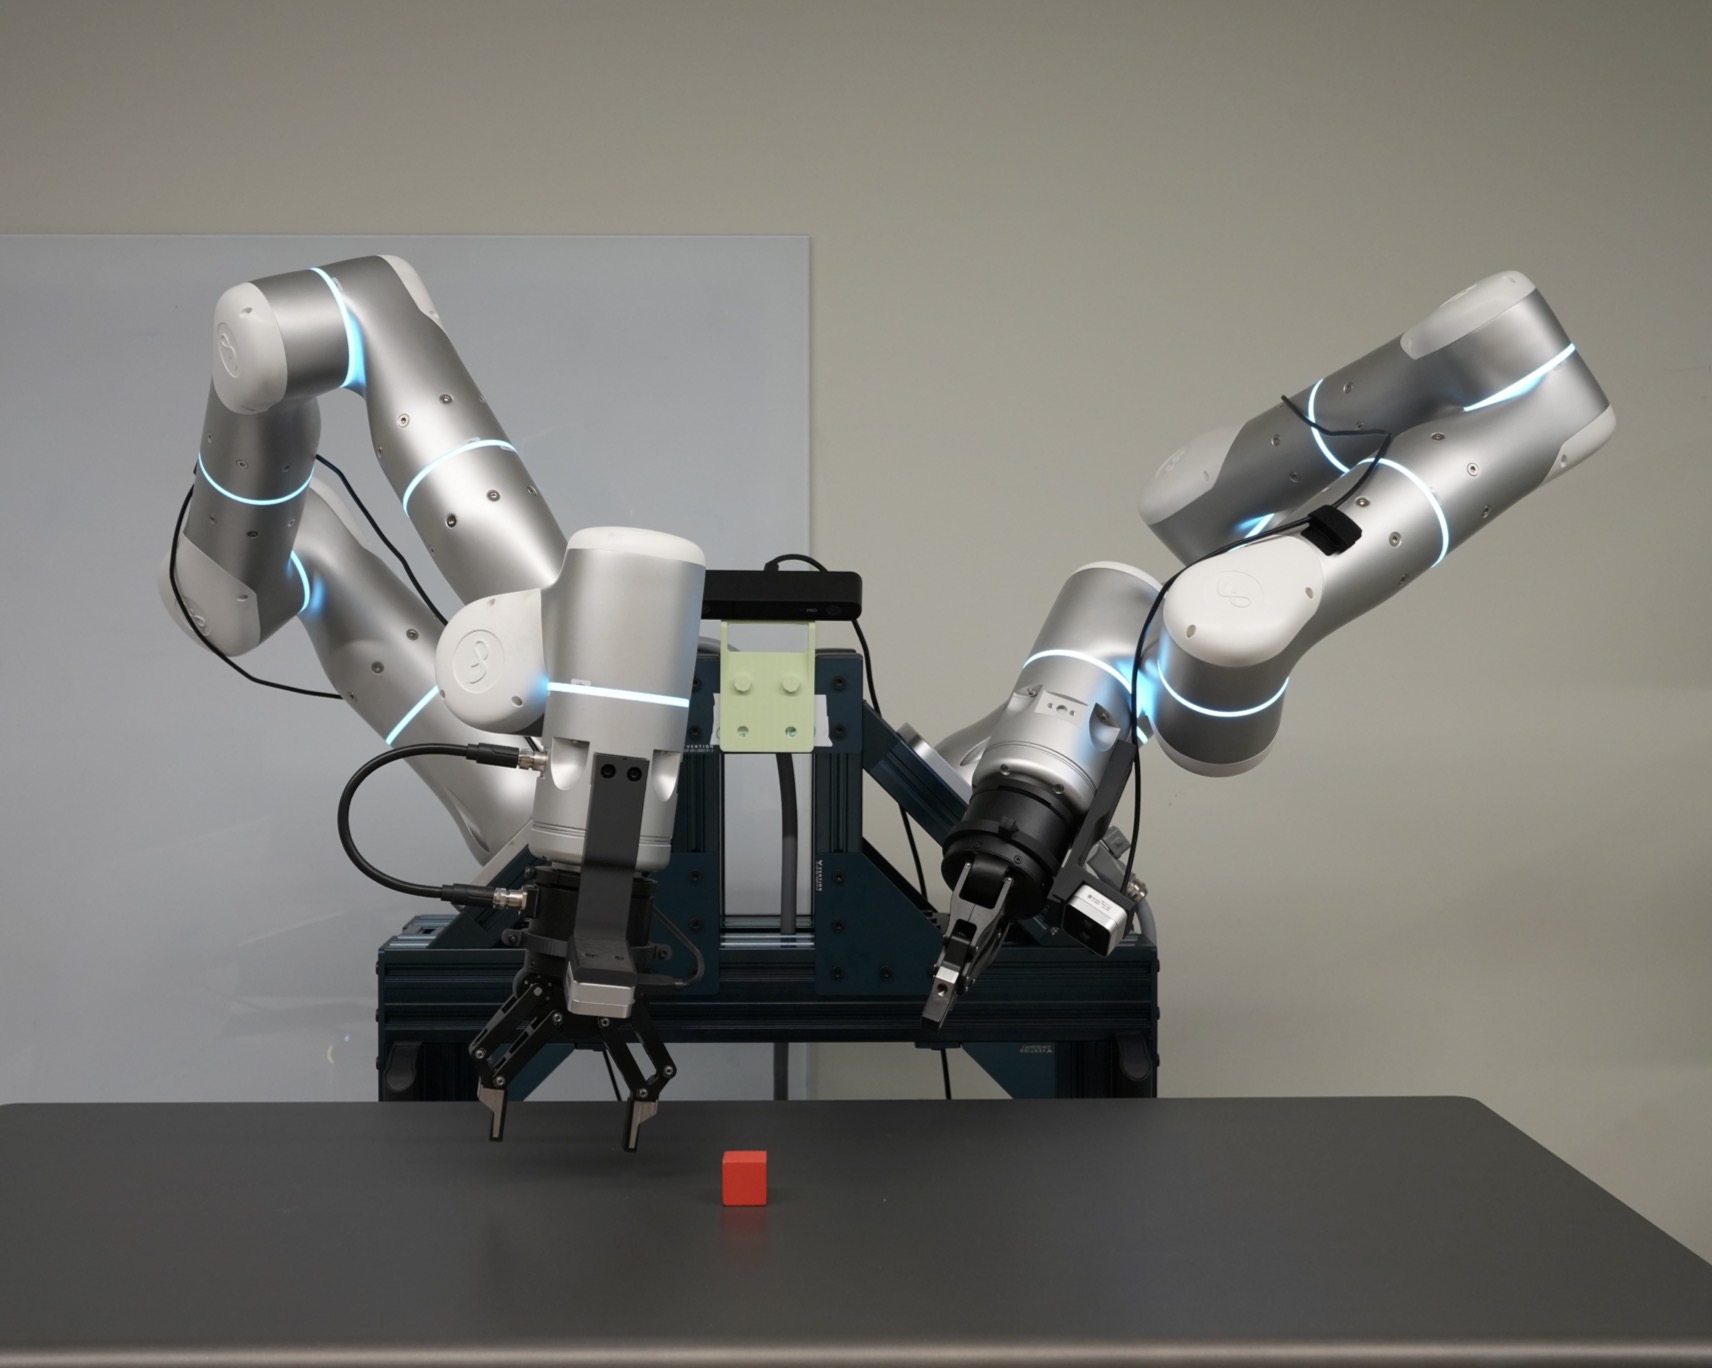
Force-Aware Manipulation
Ongoing
We investigate how force feedback can improve VLA reliability in contact-rich manipulation, using fast controllers to correct pretrained policy actions.
Kirill Utyashev

I’m seeking PhD opportunities in robot learning for Fall 2027!
Hi! I’m a fourth-year undergraduate in Computer Science at the University of Toronto. I’m fortunate to work with Prof. Florian Shkurti in the Robot Vision and Learning Lab, Prof. Peter Marbach on multi-agent reinforcement learning, and Prof. Avi Goldfarb on AI and user behavior.
My primary interests lie in robot learning, reinforcement learning, and manipulation, with the goal of developing robots that operate safely and reliably in the real world. At RVL, I investigate the visual robustness of vision-language-action models and how force feedback can improve their reliability in contact-rich manipulation.
I’m always happy to chat about research or shared interests! Feel free to reach out at kirill.utyashev@mail.utoronto.ca.
Outside research, I enjoy Brazilian jiu-jitsu (blue belt), soccer, literature, and making beats.
Ongoing
We investigate how force feedback can improve VLA reliability in contact-rich manipulation, using fast controllers to correct pretrained policy actions.
Ongoing
We investigate improving VLA visual robustness through generated scene variations tailored to the policy’s current abilities.
Ongoing
A multi-lab effort to build a dataset of real-world robot manipulation failures and suboptimal behavior. I contributed over 1,000 episodes totaling 11 hours of robot data.
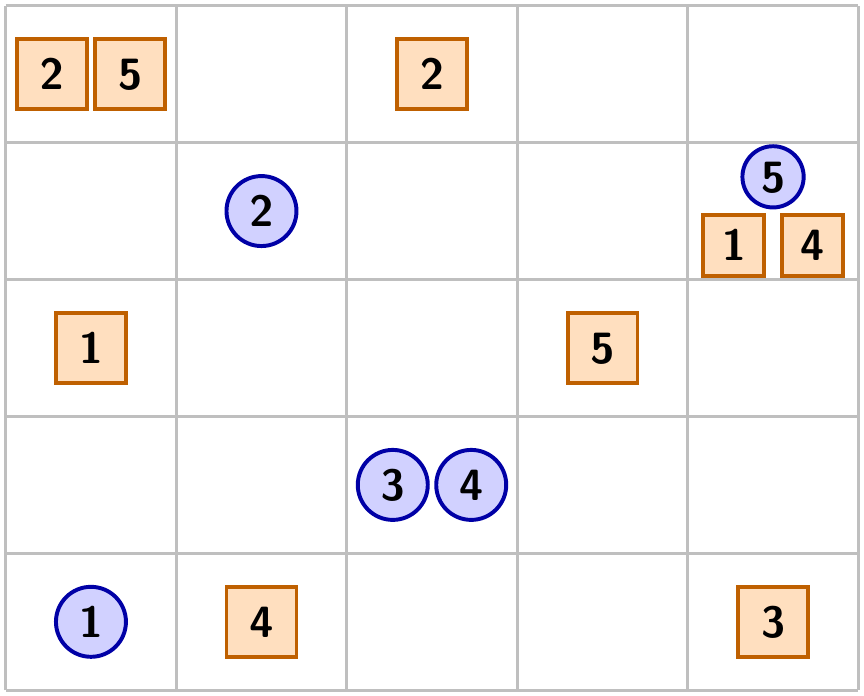
Under review
Tadd Mao*, Kirill Utyashev*, Peter Marbach
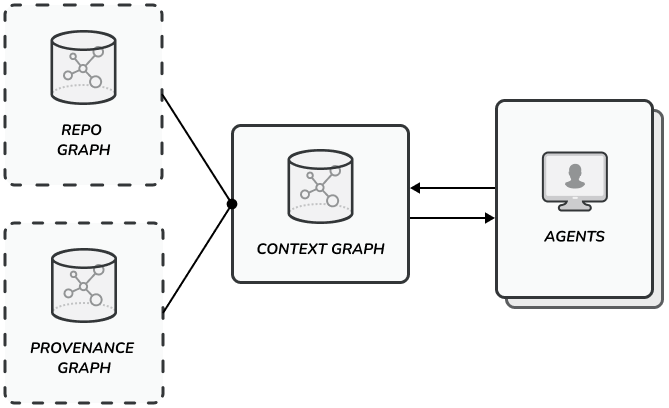
Connects code structure with context from commits, issues, and pull requests, giving coding agents repository memory grounded in its sources.

Supported by the i3 Fellowship
A toolkit for auditing LLM hiring decisions through controlled experiments and analysis of demographic bias across models and contexts.
University of Toronto
2026: Teaching Assistant, ECO102: Principles of Macroeconomics
Stanford University (Code in Place)
2025: Section Leader, Introduction to Programming in Python